


 Home
Robots Don’t Run Themselves: The Workforce Powering Physical AI
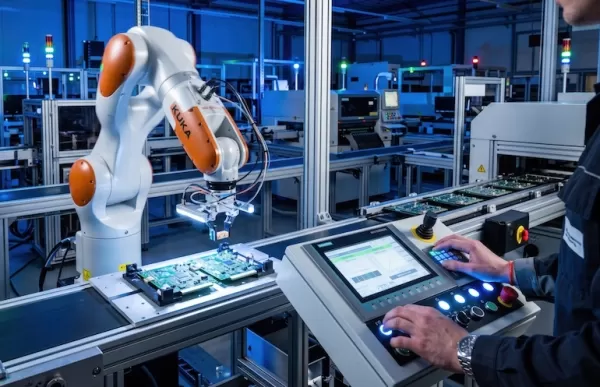
Robotic scaling demands new workforce metrics, per HireArt. Source: Lee AI, via Adobe Stock
As robotic systems transition from pilot phases to large-scale deployments, a critical pattern emerges: the bottleneck is rarely the hardware. It is the human workforce needed to operate, maintain, and continuously adapt these systems in real-world conditions.
Most robotics initiatives start with a familiar model—small, tightly coordinated teams supporting early deployments. Engineers remain close to the system, operators are highly trained, and issues are resolved quickly because everyone is involved. This structure works well when managing five or 10 robots in controlled environments.
However, this approach breaks down when deployments scale to dozens of sites across multiple shifts and inconsistent physical environments. At that point, robotics stops behaving like a product launch and starts functioning like a distributed operations business.
Physical AI deployments shift labor priorities
A useful parallel can be found in how AI labor has evolved over the past decade. Early computer vision systems relied heavily on simple, task-based data labeling that could be distributed broadly.
As models shifted toward large language models, the work itself became less about discrete tasks and more about judgment, nuance, and quality control. That change drove a shift away from loosely coordinated crowd work toward more structured, trained teams with clearer accountability.
Physical AI is now going through a similar transition, but with higher stakes. When intelligence is embodied in machines operating in warehouses, hospitals, factories, or public spaces, “quality” is no longer just a model metric. It becomes uptime, safety, hardware integrity, and customer experience in dynamic environments.
That shift exposes a gap in how many teams think about workforce design. Traditional gig-style or purely task-based labor models struggle in environments that require consistent shift coverage, safety training, site-specific protocols, and escalation procedures. In practice, many robotics deployments are finding that accountability and repeatability matter more than raw throughput.
This is driving a quiet move toward hybrid workforce structures. Some organizations are building a stable core of trained, hourly W-2 operators and technicians who own baseline execution, standard operating procedure (SOP) adherence, and escalation paths.
Around that core sits a more flexible layer of surge capacity for pilots, new site launches, and specialized deployments. While exact configurations vary, a common pattern is an even split between fixed and variable capacity, adjusted as systems mature and incident volume stabilizes.
New roles present organizational challenge
Within these teams, new role types are emerging that don’t map cleanly to traditional job families. Robot operators, field technicians, teleoperators, QA validators, and data capture specialists all sit between engineering and operations. They are responsible not only for running systems, but also for interpreting edge cases, documenting failures, and translating real-world behavior into engineering feedback loops.
In this context, incentives matter as much as structure. Speed-only metrics, common in earlier forms of digital labor, can actively degrade performance in physical environments.
Instead, teams are placing more weight on adherence to procedures, quality of documentation, escalation accuracy, and safe behavior under uncertainty.
What’s becoming clear is that scaling robotics is not just a technical challenge. It is an organizational one. Success depends on whether companies can build workforce systems that are as robust and adaptive as the machines themselves.
In other words, the next phase of robotics scaling won’t be defined only by better autonomy. It will be defined by whether teams can reliably scale human judgment alongside machine intelligence, across sites, shifts, and real-world conditions that rarely behave as expected.
 About the author
Christopher Bower is co-founder, chief revenue officer, and president of HireArt, which provides a contract-for-hire platform. The New York-based company’s stated mission is to reinvent flexible employment by connecting workers and businesses and supporting their productivity.
HireArt said its tool allows customers to build and manage a modern contract workforce with a single tool. They can handle employer of record, on-demand sourcing, vendor management, and freelancer management, all in the same self-serve user interface.
Bower has worked at HumanEdge, Tandym Group, and Access Confidential. He is also a voluntary career coach at the New York Public Library.
Related article
 ARM Institute Secures $90M to Modernize Military Manufacturing Through 10 New Projects
The ARM Institute collaborates with over 500 member organizations and partners spanning industry, academia, and government sectors. | Source: ARM InstituteThis week, the Advanced Robotics for Manufacturing (ARM) Institute was awarded nearly $90 milli
Amazon’s Bhavana Chandrashekhar to Address RoboBusiness Women in Robotics Lunch
From left to right: Bhavana Chandrashekhar and Joyce Sidopoulos.Women currently represent only 35% of the global STEM workforce and 22% of the global AI workforce, leaving many robotics professionals isolated from peer support.Join us at RoboBusiness
GM's Mikell Taylor to Headline Women in Robotics Breakfast at Robotics Summit
Mikell Taylor, GM's Head of Robotics Strategy, will discuss the critical role of trust at the Robotics Summit & Expo.According to CareerExplorer, women currently make up only 19% of robotics engineers. This statistic means that many women at smaller
Related Special Topic Recommendations
Image editing
 AI Object Removal Editors: Clean Up Portraits, Travel, and Product Shots
2026 Latest Best Top-rated AI Object Removal Editors for portraits travel product shots! XIX.AI curates a powerful game-changing collection regularly updated with weekly rankings. These tools offer real-world tests to help you quickly remove unwanted elements, boost content quality, and save tons of time without compromising results. Must-try for anyone aiming to unlock their AI creation edge. Explore now!
 10 tools
 xix.ai
Text-to-speech
Best AI Text to Speech Tools for Online Courses
2026 Latest Best Top-rated AI Text to Speech Tools for Online Courses are curated by XIX.AI based on rigorous real-world tests and weekly updated rankings. These powerful tools help creators deliver crystal-clear audio content effortlessly, boosting writing efficiency and streamlining course production. Check out the free vs paid comparison to find your perfect fit. Explore now to unlock your AI edge in online education.
10 tools
xix.ai
writing
AI Blog Title Tools for Higher Click Through Rates
2026 Latest Best Top-Rated AI Blog Title Tools for Higher Click Through Rates! XIX.AI has carefully curated a powerful, game-changing collection of top tools that go through rigorous real-world tests. You’ll find a free vs paid comparison, weekly updated rankings, and detailed insights to help you boost your blog’s traffic efficiently. Must-try options are highlighted to help you unlock your AI edge. Explore now!
10 tools
xix.ai
automation
Best AI Task Routing Tools for Support Workflows
2026 Latest Best Top-rated AI Task Routing Tools for Support Workflows! XIX.AI has curated a highly powerful game-changing collection of must-try solutions, all undergoing rigorous real-world tests and updated weekly. These tools streamline workflows, boost productivity, and help teams deliver faster, more efficient support. Explore now to discover your perfect tool and unlock your AI edge!
17 tools
xix.ai
Academic Research
AI Citation and Paper Summary Tools
2026 Latest Best Top-Rated AI Citation and Paper Summary Tools Curated by XIX.AI. Get powerful game-changing solutions for quick content creation, improved writing efficiency, and boosting productivity. We offer a free vs paid comparison along with real-world tests and weekly updated rankings to help you find the must-try tool that fits your needs perfectly. Explore now to Unlock your AI edge.
10 tools
xix.ai
Productivity
Best AI Productivity Tools for Daily Work
2026 Latest Best Top-Rated AI Productivity Tools for Daily Work! XIX.AI has curated a powerful, game-changing selection based on rigorous weekly updated rankings and real-world tests. You’ll find must-try options that boost writing efficiency, streamline content creation, and help you overcome daily work challenges. Get a free vs paid comparison to find the perfect fit for your needs. Explore now to unlock your AI edge!
9 tools
xix.ai

 Comments (0)
0/500
Robotic scaling demands new workforce metrics, per HireArt. Source: Lee AI, via Adobe Stock
As robotic systems transition from pilot phases to large-scale deployments, a critical pattern emerges: the bottleneck is rarely the hardware. It is the human workforce needed to operate, maintain, and continuously adapt these systems in real-world conditions.
Most robotics initiatives start with a familiar model—small, tightly coordinated teams supporting early deployments. Engineers remain close to the system, operators are highly trained, and issues are resolved quickly because everyone is involved. This structure works well when managing five or 10 robots in controlled environments.
However, this approach breaks down when deployments scale to dozens of sites across multiple shifts and inconsistent physical environments. At that point, robotics stops behaving like a product launch and starts functioning like a distributed operations business.
Physical AI deployments shift labor priorities
A useful parallel can be found in how AI labor has evolved over the past decade. Early computer vision systems relied heavily on simple, task-based data labeling that could be distributed broadly.
As models shifted toward large language models, the work itself became less about discrete tasks and more about judgment, nuance, and quality control. That change drove a shift away from loosely coordinated crowd work toward more structured, trained teams with clearer accountability.
Physical AI is now going through a similar transition, but with higher stakes. When intelligence is embodied in machines operating in warehouses, hospitals, factories, or public spaces, “quality” is no longer just a model metric. It becomes uptime, safety, hardware integrity, and customer experience in dynamic environments.
That shift exposes a gap in how many teams think about workforce design. Traditional gig-style or purely task-based labor models struggle in environments that require consistent shift coverage, safety training, site-specific protocols, and escalation procedures. In practice, many robotics deployments are finding that accountability and repeatability matter more than raw throughput.
This is driving a quiet move toward hybrid workforce structures. Some organizations are building a stable core of trained, hourly W-2 operators and technicians who own baseline execution, standard operating procedure (SOP) adherence, and escalation paths.
Around that core sits a more flexible layer of surge capacity for pilots, new site launches, and specialized deployments. While exact configurations vary, a common pattern is an even split between fixed and variable capacity, adjusted as systems mature and incident volume stabilizes.
New roles present organizational challenge
Within these teams, new role types are emerging that don’t map cleanly to traditional job families. Robot operators, field technicians, teleoperators, QA validators, and data capture specialists all sit between engineering and operations. They are responsible not only for running systems, but also for interpreting edge cases, documenting failures, and translating real-world behavior into engineering feedback loops.
In this context, incentives matter as much as structure. Speed-only metrics, common in earlier forms of digital labor, can actively degrade performance in physical environments.
Instead, teams are placing more weight on adherence to procedures, quality of documentation, escalation accuracy, and safe behavior under uncertainty.
What’s becoming clear is that scaling robotics is not just a technical challenge. It is an organizational one. Success depends on whether companies can build workforce systems that are as robust and adaptive as the machines themselves.
In other words, the next phase of robotics scaling won’t be defined only by better autonomy. It will be defined by whether teams can reliably scale human judgment alongside machine intelligence, across sites, shifts, and real-world conditions that rarely behave as expected.
About the author
Christopher Bower is co-founder, chief revenue officer, and president of HireArt, which provides a contract-for-hire platform. The New York-based company’s stated mission is to reinvent flexible employment by connecting workers and businesses and supporting their productivity.
HireArt said its tool allows customers to build and manage a modern contract workforce with a single tool. They can handle employer of record, on-demand sourcing, vendor management, and freelancer management, all in the same self-serve user interface.
Bower has worked at HumanEdge, Tandym Group, and Access Confidential. He is also a voluntary career coach at the New York Public Library.








 ARM Institute Secures $90M to Modernize Military Manufacturing Through 10 New Projects
The ARM Institute collaborates with over 500 member organizations and partners spanning industry, academia, and government sectors. | Source: ARM InstituteThis week, the Advanced Robotics for Manufacturing (ARM) Institute was awarded nearly $90 milli
 Amazon’s Bhavana Chandrashekhar to Address RoboBusiness Women in Robotics Lunch
From left to right: Bhavana Chandrashekhar and Joyce Sidopoulos.Women currently represent only 35% of the global STEM workforce and 22% of the global AI workforce, leaving many robotics professionals isolated from peer support.Join us at RoboBusiness
 GM's Mikell Taylor to Headline Women in Robotics Breakfast at Robotics Summit
Mikell Taylor, GM's Head of Robotics Strategy, will discuss the critical role of trust at the Robotics Summit & Expo.According to CareerExplorer, women currently make up only 19% of robotics engineers. This statistic means that many women at smaller

2026 Latest Best Top-rated AI Object Removal Editors for portraits travel product shots! XIX.AI curates a powerful game-changing collection regularly updated with weekly rankings. These tools offer real-world tests to help you quickly remove unwanted elements, boost content quality, and save tons of time without compromising results. Must-try for anyone aiming to unlock their AI creation edge. Explore now!
10 tools
xix.ai

2026 Latest Best Top-rated AI Text to Speech Tools for Online Courses are curated by XIX.AI based on rigorous real-world tests and weekly updated rankings. These powerful tools help creators deliver crystal-clear audio content effortlessly, boosting writing efficiency and streamlining course production. Check out the free vs paid comparison to find your perfect fit. Explore now to unlock your AI edge in online education.
10 tools
xix.ai

2026 Latest Best Top-Rated AI Blog Title Tools for Higher Click Through Rates! XIX.AI has carefully curated a powerful, game-changing collection of top tools that go through rigorous real-world tests. You’ll find a free vs paid comparison, weekly updated rankings, and detailed insights to help you boost your blog’s traffic efficiently. Must-try options are highlighted to help you unlock your AI edge. Explore now!
10 tools
xix.ai

2026 Latest Best Top-rated AI Task Routing Tools for Support Workflows! XIX.AI has curated a highly powerful game-changing collection of must-try solutions, all undergoing rigorous real-world tests and updated weekly. These tools streamline workflows, boost productivity, and help teams deliver faster, more efficient support. Explore now to discover your perfect tool and unlock your AI edge!
17 tools
xix.ai

2026 Latest Best Top-Rated AI Citation and Paper Summary Tools Curated by XIX.AI. Get powerful game-changing solutions for quick content creation, improved writing efficiency, and boosting productivity. We offer a free vs paid comparison along with real-world tests and weekly updated rankings to help you find the must-try tool that fits your needs perfectly. Explore now to Unlock your AI edge.
10 tools
xix.ai

2026 Latest Best Top-Rated AI Productivity Tools for Daily Work! XIX.AI has curated a powerful, game-changing selection based on rigorous weekly updated rankings and real-world tests. You’ll find must-try options that boost writing efficiency, streamline content creation, and help you overcome daily work challenges. Get a free vs paid comparison to find the perfect fit for your needs. Explore now to unlock your AI edge!
9 tools
xix.ai












