


 Home
Li Feifei’s Team Unveils Method to Generate Infinite Robot Training Grounds From Single Video
In embodied intelligence, bridging the gap from simulation to reality—known as "Sim2Real"—has long been a persistent hurdle. Simulation setups are expensive, and models frequently lose performance when deployed in physical settings. A recent collaborative study from Li Fei-Fei’s team, NVIDIA GEAR Lab, and Georgia Tech introduces a novel solution: Real2Sim.
Named "SimFoundry," this system creates interactive, trainable, and testable robotic simulations using simple real-world video. Going beyond traditional 3D reconstruction, SimFoundry performs deep scene analysis to automate environment creation, drastically reducing the effort required to build simulations.
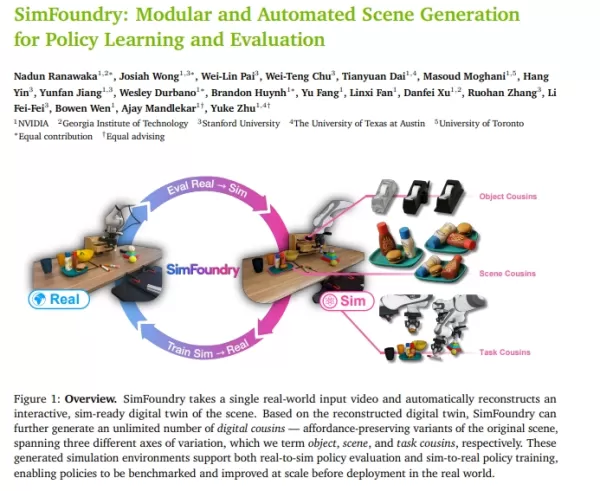
SimFoundry’s core innovation involves a closed loop between "digital twins" and "digital cousins." The system extracts geometric, physical, and interactive data from videos to build high-fidelity digital twins. It then automatically varies appearance, layout, and tasks to generate diverse digital cousins. This allows developers to derive virtually unlimited training data from a single video, enabling end-to-end strategy learning and evaluation within the simulation.
Experiments confirm SimFoundry’s strong predictive power, with simulated robot performance closely matching real-world outcomes. Crucially, strategies trained on this synthetic data transfer effectively to reality without fine-tuning ("zero-shot"), excelling in complex tasks like multi-step operations and dual-arm coordination.
Co-authored by leading robotics experts, including key members of NVIDIA GEAR Lab and Li Fei-Fei’s team, this open-source system promises to transform embodied AI development. By replacing costly manual data collection with generative technology, robots can now transition from lab to real-world applications much faster.
Paper link: https://arxiv.org/pdf/2606.28276v1
Related article
 Anthropic Launches Claude Mythos to Solve Erdős Conjecture With Concise Proof
On May 26, Sholto Douglas, an engineer at Anthropic, took to X to announce that their latest model, Claude Mythos, had cracked a century-old puzzle in combinatorial geometry: the Erdős unit distance conjecture. Dubbed a "clever and concise proof," th
Amazon to Acquire Decart for $7B, Securing Key AI Chip Adapter
Per the Wall Street Journal, Amazon is negotiating to purchase AI startup Decart at an estimated $7 billion valuation. If no competing bids arise, the transaction could close shortly, underscoring major tech firms’ urgency to secure computing resourc
How Locus tackles one of robotics' biggest challenges: manipulation
NeuraGrasp handles diverse items, including small containers, porous polybags, and textiles. | Source: Locus RoboticsLocus Robotics Corp. has solved numerous robotic hurdles in live operational settings. Its autonomous mobile robots (AMRs) have trave
Related Special Topic Recommendations
Design & Art
 Top AI Illustration Tools: Create Editorial Scenes and Cover Art Faster
2026 Latest Top-rated AI Illustration Tools: Our curated list features the best powerfully designed tools for creating stunning editorial scenes and eye-catching cover art quickly. Each option has gone through rigorous real-world tests, offering a free vs paid comparison to help you find the perfect match for your workflow. Try these must-try solutions today to unlock your AI edge and boost your creative productivity. Explore now at XIX.AI.
 10 tools
 xix.ai
Education and Learning
Top AI Tutors for Exam Prep: Practice Math, Science, and English
2026 Latest Top-Rated Best AI Tutors for Exam Prep are here on XIX.AI! Our curated list features powerful game-changing tools that offer free vs paid comparison, real-world tests, and weekly updated rankings. They help boost your writing efficiency, simplify complex topic learning, and unlock your academic potential. Explore now to Discover your perfect exam prep tool and Start creating today to Unlock your AI edge!
10 tools
xix.ai
Finance
AI Budget Planning Tools for Personal Money Management
2026 Latest Best Top-Rated AI Budget Planning Tools for Personal Money Management are here on XIX.AI! This curated collection features powerful, game-changing solutions that help you conduct real-world tests, understand spending habits, and create personalized plans to boost productivity. Enjoy a free vs paid comparison along with detailed rankings. Must-try tools designed to simplify money management and unlock your AI edge. Explore now!
11 tools
xix.ai
Health & Wellness
AI Sleep Tracking Assistants: Improve Recovery with Better Bedtime Habits
2026 Latest Best Top-Rated AI Sleep Tracking Assistants curated for ultimate recovery. This fully updated weekly guide features powerful tools that deliver real-world tests, free vs paid comparison, and detailed rankings to help you find the must-try solution that boosts sleep quality and supports better bedtime habits. Explore now at XIX.AI to Unlock your AI edge.
10 tools
xix.ai
Data Analysis
AI SQL Copilots for Product and Revenue Analytics
2026 Latest Best Top-Rated AI SQL Copilots for Product and Revenue Analytics! XIX.AI has curated a powerful, game-changing collection of must-try tools that undergo real-world tests through weekly updated rankings. These tools help users boost productivity significantly by accelerating data analysis, streamlining complex queries, and generating accurate insights to drive smarter business decisions. Explore now to Discover your perfect tool for unlocking your AI edge!
14 tools
xix.ai
Education and Learning
Best AI Homework Helpers That Teach: Learn Concepts, Not Just Answers
2026 Latest Best Top-Rated AI Homework Helpers That Teach Core Concepts Not Just Answers Powerful Tools for Students Must-Try Curated List Weekly Updated Free vs Paid Comparison Real-World Tests Accurate Rankings to Help You Unlock Your Full Learning Potential Explore now to Discover your perfect tool for smarter studying.
10 tools
xix.ai

 Comments (0)
0/500
In embodied intelligence, bridging the gap from simulation to reality—known as "Sim2Real"—has long been a persistent hurdle. Simulation setups are expensive, and models frequently lose performance when deployed in physical settings. A recent collaborative study from Li Fei-Fei’s team, NVIDIA GEAR Lab, and Georgia Tech introduces a novel solution: Real2Sim.
Named "SimFoundry," this system creates interactive, trainable, and testable robotic simulations using simple real-world video. Going beyond traditional 3D reconstruction, SimFoundry performs deep scene analysis to automate environment creation, drastically reducing the effort required to build simulations.
SimFoundry’s core innovation involves a closed loop between "digital twins" and "digital cousins." The system extracts geometric, physical, and interactive data from videos to build high-fidelity digital twins. It then automatically varies appearance, layout, and tasks to generate diverse digital cousins. This allows developers to derive virtually unlimited training data from a single video, enabling end-to-end strategy learning and evaluation within the simulation.
Experiments confirm SimFoundry’s strong predictive power, with simulated robot performance closely matching real-world outcomes. Crucially, strategies trained on this synthetic data transfer effectively to reality without fine-tuning ("zero-shot"), excelling in complex tasks like multi-step operations and dual-arm coordination.
Co-authored by leading robotics experts, including key members of NVIDIA GEAR Lab and Li Fei-Fei’s team, this open-source system promises to transform embodied AI development. By replacing costly manual data collection with generative technology, robots can now transition from lab to real-world applications much faster.
Paper link: https://arxiv.org/pdf/2606.28276v1








 Anthropic Launches Claude Mythos to Solve Erdős Conjecture With Concise Proof
On May 26, Sholto Douglas, an engineer at Anthropic, took to X to announce that their latest model, Claude Mythos, had cracked a century-old puzzle in combinatorial geometry: the Erdős unit distance conjecture. Dubbed a "clever and concise proof," th
 Amazon to Acquire Decart for $7B, Securing Key AI Chip Adapter
Per the Wall Street Journal, Amazon is negotiating to purchase AI startup Decart at an estimated $7 billion valuation. If no competing bids arise, the transaction could close shortly, underscoring major tech firms’ urgency to secure computing resourc
How Locus tackles one of robotics' biggest challenges: manipulation
NeuraGrasp handles diverse items, including small containers, porous polybags, and textiles. | Source: Locus RoboticsLocus Robotics Corp. has solved numerous robotic hurdles in live operational settings. Its autonomous mobile robots (AMRs) have trave

2026 Latest Top-rated AI Illustration Tools: Our curated list features the best powerfully designed tools for creating stunning editorial scenes and eye-catching cover art quickly. Each option has gone through rigorous real-world tests, offering a free vs paid comparison to help you find the perfect match for your workflow. Try these must-try solutions today to unlock your AI edge and boost your creative productivity. Explore now at XIX.AI.
10 tools
xix.ai

2026 Latest Top-Rated Best AI Tutors for Exam Prep are here on XIX.AI! Our curated list features powerful game-changing tools that offer free vs paid comparison, real-world tests, and weekly updated rankings. They help boost your writing efficiency, simplify complex topic learning, and unlock your academic potential. Explore now to Discover your perfect exam prep tool and Start creating today to Unlock your AI edge!
10 tools
xix.ai

2026 Latest Best Top-Rated AI Budget Planning Tools for Personal Money Management are here on XIX.AI! This curated collection features powerful, game-changing solutions that help you conduct real-world tests, understand spending habits, and create personalized plans to boost productivity. Enjoy a free vs paid comparison along with detailed rankings. Must-try tools designed to simplify money management and unlock your AI edge. Explore now!
11 tools
xix.ai

2026 Latest Best Top-Rated AI Sleep Tracking Assistants curated for ultimate recovery. This fully updated weekly guide features powerful tools that deliver real-world tests, free vs paid comparison, and detailed rankings to help you find the must-try solution that boosts sleep quality and supports better bedtime habits. Explore now at XIX.AI to Unlock your AI edge.
10 tools
xix.ai

2026 Latest Best Top-Rated AI SQL Copilots for Product and Revenue Analytics! XIX.AI has curated a powerful, game-changing collection of must-try tools that undergo real-world tests through weekly updated rankings. These tools help users boost productivity significantly by accelerating data analysis, streamlining complex queries, and generating accurate insights to drive smarter business decisions. Explore now to Discover your perfect tool for unlocking your AI edge!
14 tools
xix.ai

2026 Latest Best Top-Rated AI Homework Helpers That Teach Core Concepts Not Just Answers Powerful Tools for Students Must-Try Curated List Weekly Updated Free vs Paid Comparison Real-World Tests Accurate Rankings to Help You Unlock Your Full Learning Potential Explore now to Discover your perfect tool for smarter studying.
10 tools
xix.ai












